In this article
Physical AI turns perception and reasoning into useful physical work: moving packages, tending machines, removing weeds, assisting procedures, or inspecting infrastructure. For businesses, its value depends on a measurable job and the full cost of delivering it.
This guide combines two charts, five use-case domains, and 25 startup profiles, checked on September 6, 2026. Start with the market estimate, use the circle to find your domain, then compare the companies and adaptation requirements.
What is physical AI?
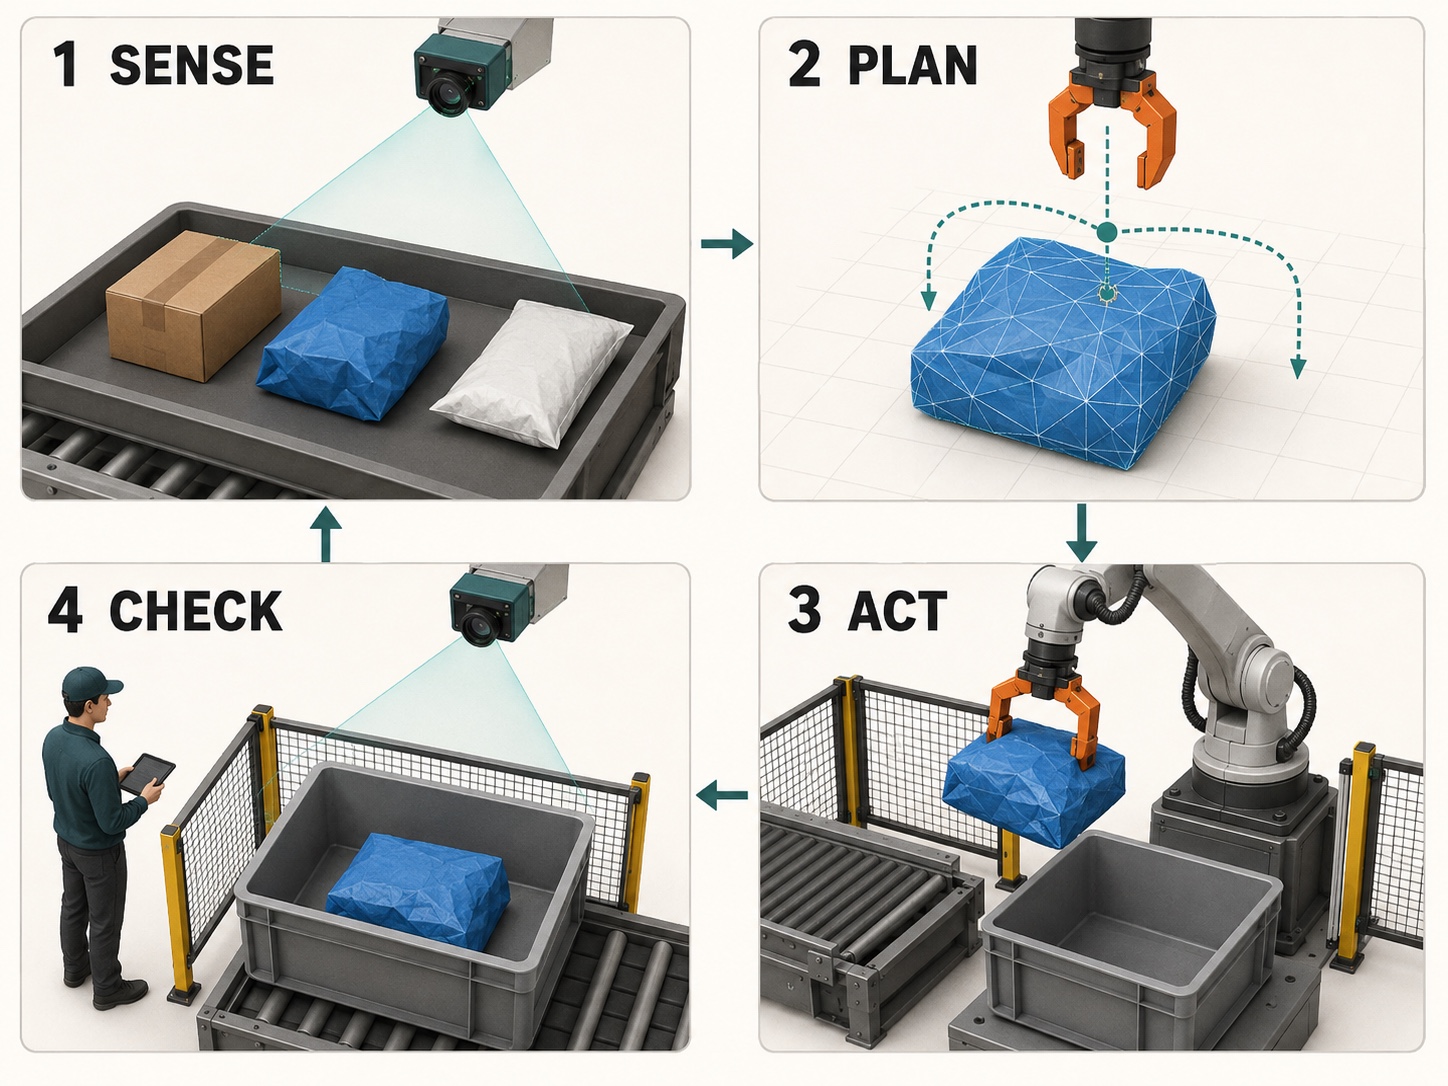
Physical AI connects AI to machines that sense their surroundings and act on them. A packing robot, for example, recognizes a changed parcel, adjusts its grip, moves it, and checks placement. A humanoid is one possible body; wheels, arms, and specialized devices often fit the task better. Broader definitions also include vehicles and intelligent infrastructure. Deloitte’s overview .
Market valuation estimate: how large could it become?
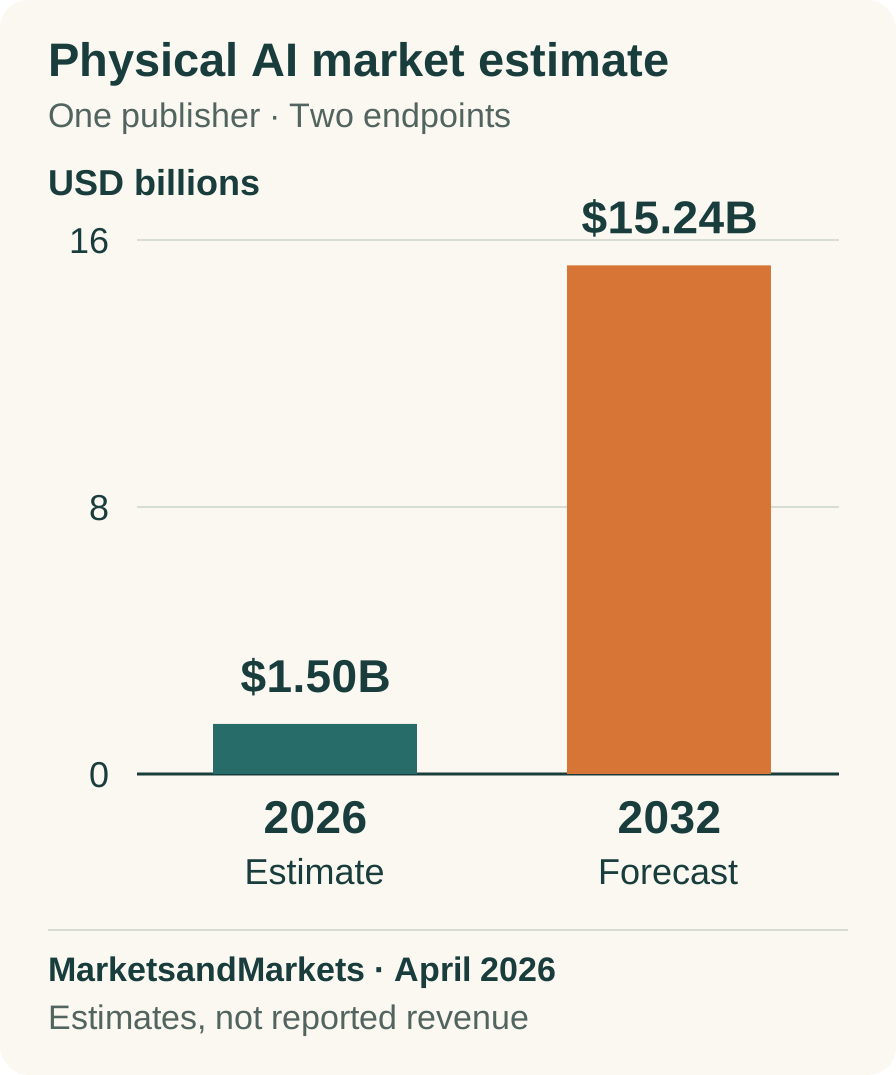
Here, market value means estimated market revenue, not startup equity valuations. MarketsandMarkets estimates $1.50 billion in 2026 and forecasts $15.24 billion in 2032, with a stated 47.2% annual compound growth rate. These are one publisher’s estimates for its defined physical AI category, not observed sales totals. April 2026 report , April 3 publisher announcement .
Other widely cited estimates answer different questions:
| Publisher and publication | Estimate | Scope |
|---|---|---|
| PwC, June 2026 | About $450B by 2030 | Defined core physical AI market |
| Goldman Sachs, February 2024 | $38B by 2035 | Humanoid robot addressable market |
| Morgan Stanley, May 2025 | About $5T by 2050 | Long-horizon humanoid scenario |
Do not combine these into one growth curve or add them together. Their definitions, horizons, and assumptions differ. A business plan should estimate reachable customers and task-level spending within its chosen segment.
For observed demand, IFR reports 542,000 industrial robot installations in 2024 and 4.664 million robots in use. Its June 2026 presentation puts preliminary 2025 installations at 621,000, up 15%; final results were scheduled for September 24. These include conventional robots and are not a physical AI census. Finalized IFR statistics , preliminary update, slides 4–5 .
The use-case circle: five domains, five business purposes
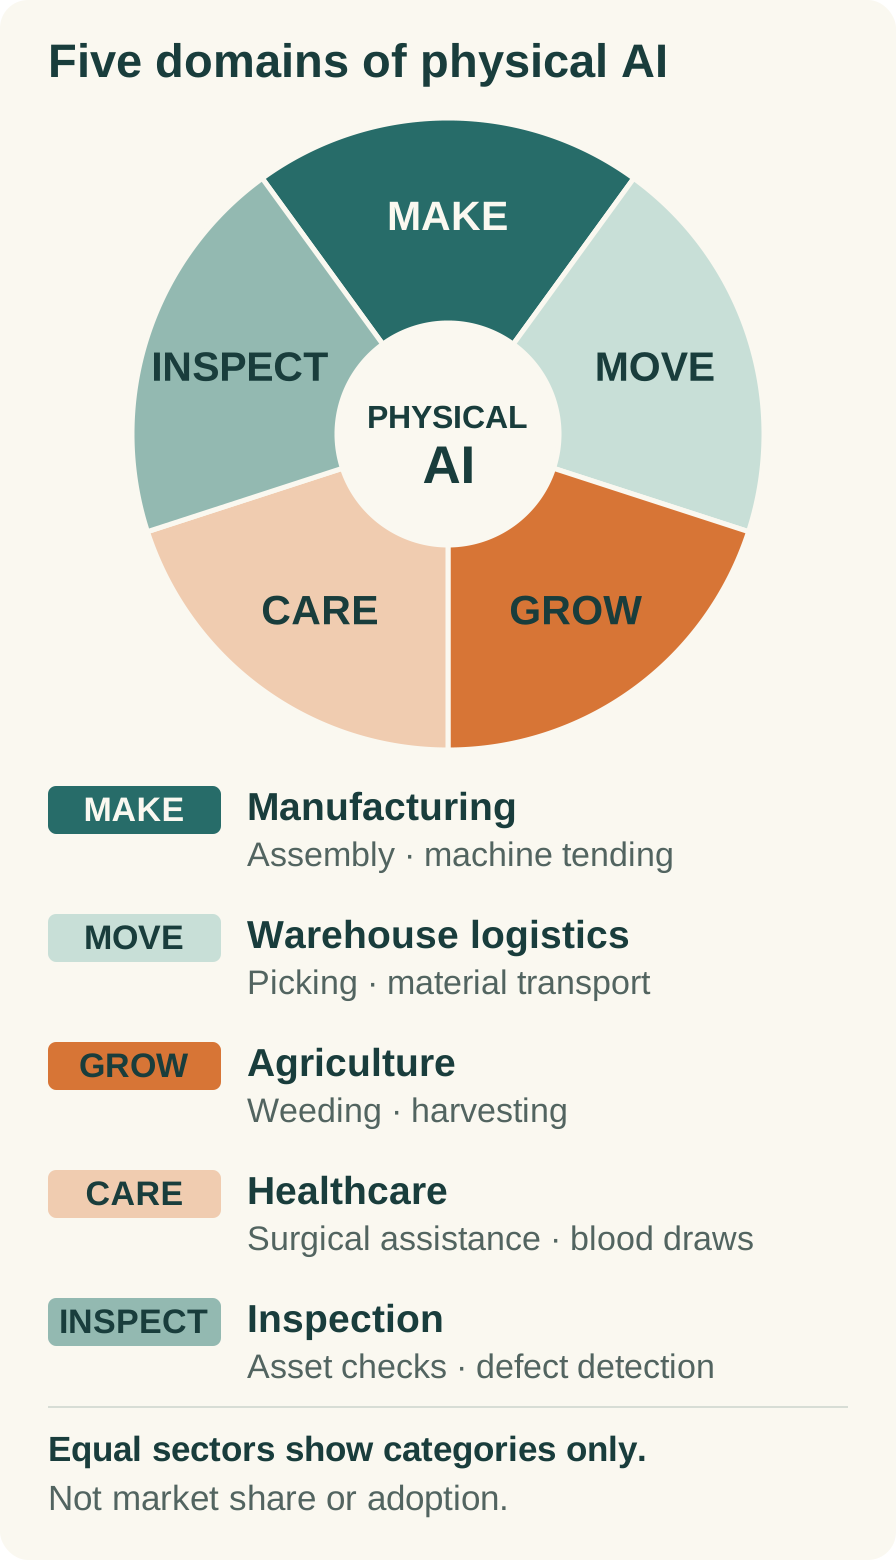
The circle groups applications by their main purpose. Equal segments show categories, not market share, adoption rates, or equal commercial maturity. Some companies span several domains; each appears once under the workflow discussed here. This is a selected business map, not an exhaustive taxonomy of physical AI.
25 promising startups, grouped by use case
“Promising” means a relevant product plus public evidence of technical progress, customer activity, or clinical development. This is an editorial shortlist, not a ranking or investment recommendation. Evidence ranges from trials to operating deployments; the labels make that distinction visible.
These company-website screenshots were captured on September 6, 2026, except the Gecko Robotics image refreshed on September 20. Click to enlarge; source links identify the page. Website imagery and claims belong to the respective companies and do not establish independently verified performance.
Manufacturing: make and assemble
Purpose: improve handling, machine tending, and assembly when parts or positions vary. Adaptation: grippers, fixtures, machine interfaces, force limits, and product changeovers. Measure accepted parts per scheduled hour and rework.
1. Figure
Factory pilot
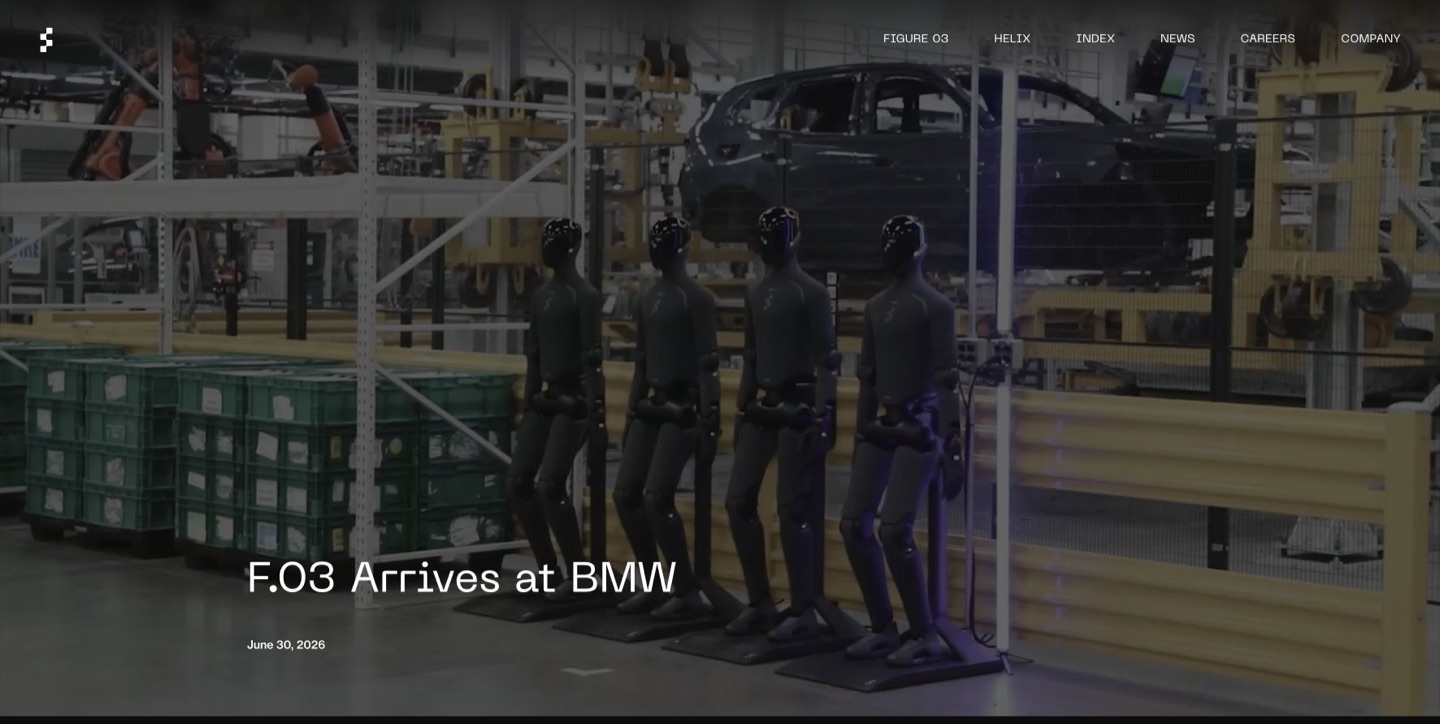
Humanoids for variable factory work. BMW provides a named industrial test site; Figure 03’s component-sequencing project follows the earlier Figure 02 pilot. Production economics remain undisclosed.
Figure’s BMW example explains why a humanoid might be useful: the work combines picking parts with moving the body and a cart. In the June 2026 demonstration , Figure 03 handles component sequencing, where the orientation of incoming parts varies. This is a different task and robot generation from Figure 02’s earlier sheet-metal loading work. Evidence from one should not be treated as a measured production result for the other.
For an automotive supplier, the purchasing question is whether that flexibility compensates for the cost and complexity of a walking robot. A useful trial would include awkward part orientations, cart repositioning, missed picks, and restart time over complete shifts. Compare accepted sequences per scheduled hour with a fixed arm, a redesigned fixture, and the existing manual process. A successful demonstration establishes feasibility; it does not disclose those operating economics.
2. Apptronik
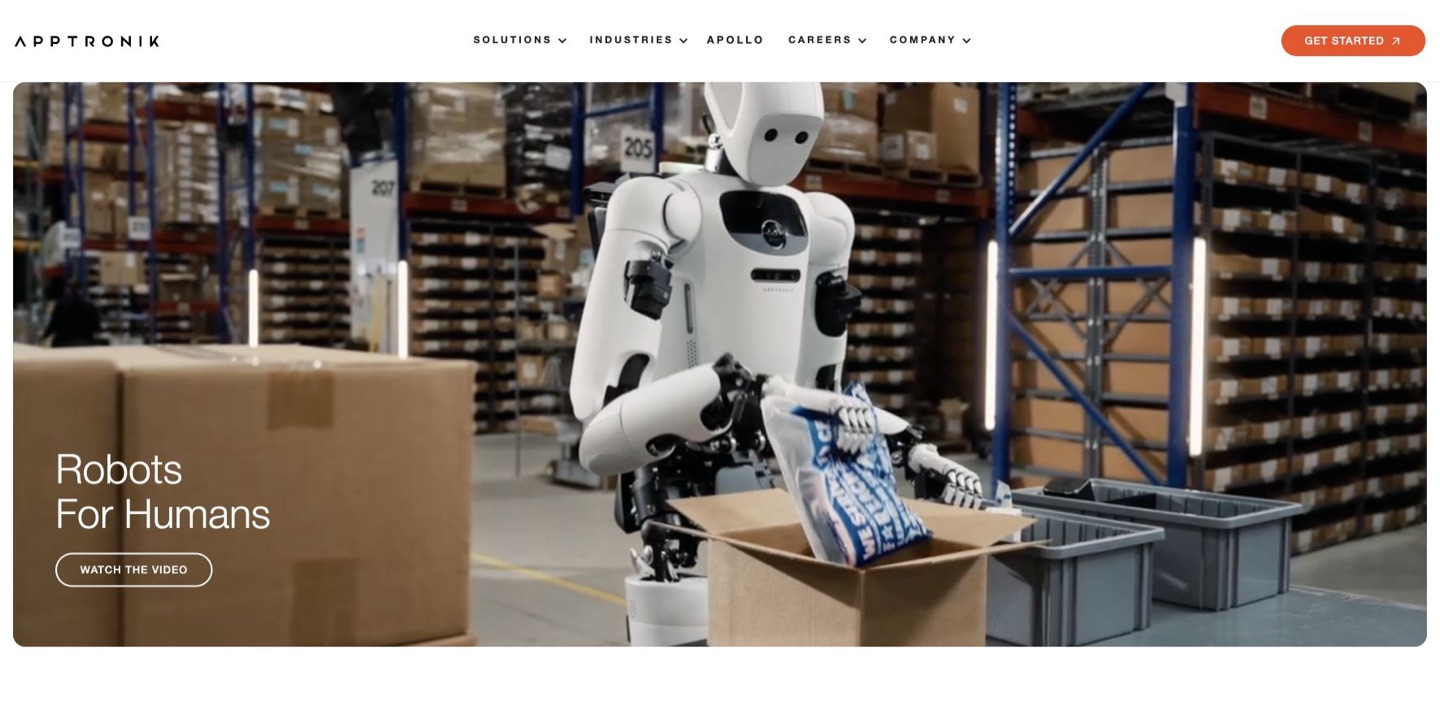
Industrial pilots
Apollo targets kitting, material handling, and fixture placement. Jabil’s collaboration combines robot manufacturing with factory pilots, offering a route to test humanoids within existing production processes.
Apollo’s relevant starting point is repetitive work between manufacturing stations. The Jabil collaboration names kitting, inspection, sorting, lineside delivery, and fixture placement as pilot tasks. Jabil also participates in manufacturing Apollo itself. Those two roles matter: a partner helping build the robot is not, by that fact alone, evidence that every proposed factory application is running commercially.
A buyer should define one handoff precisely—for example, delivering a complete kit to a fixture—and test it before adding more tasks. Count incomplete kits, waiting at occupied stations, charging interruptions, and operator interventions. The attractive possibility is reusing one robot across changing assignments; the economic case depends on the time and support needed to teach each assignment and keep it working when the factory layout or part mix changes.
3. Standard Bots
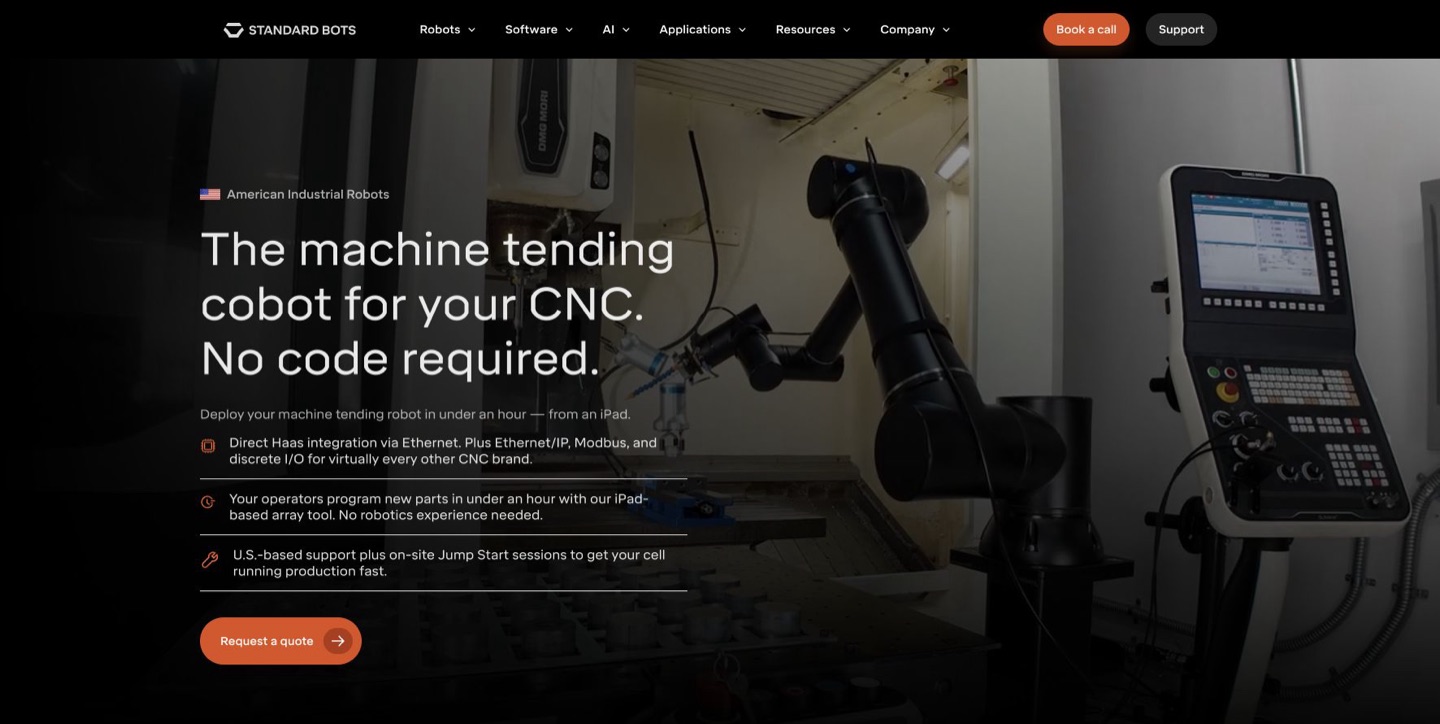
Commercial offering
Industrial arms for machine tending, welding, and handling. Its no-code setup and onsite pilot program make it worth evaluating for smaller manufacturers; confirm the AI capability required by your application.
Standard Bots offers a more bounded route to automation than a general-purpose humanoid: an arm, gripper, machine interface, and operator setup tools around a specific cell. Its machine-tending offering distinguishes self-installation, assisted setup, and full integration. That distinction affects the real purchase price because the same robot can require very different amounts of engineering and staff time at different factories.
For a CNC shop, evaluate the complete load–machine–unload cycle, including door control, part positioning, chip removal, and recovery after a failed grip. A fast robot adds little capacity if the machine cycle already determines throughput. Ask which part variations need AI perception and which are handled by repeatable programming. The useful comparison is cost per accepted part and changeover effort for the shop’s actual jobs, rather than an AI label or arm speed alone.
4. RobCo
Named customers
Modular robots, software, and integration through a service model. Named industrial customers support its handling and machine-tending proposition; buyers should compare service fees and application-specific performance.
RobCo’s proposition combines modular hardware with deployment software and integration support. That makes it relevant when a manufacturer wants automation for a defined handling or machine-tending task but lacks a large internal robotics team. The linked company announcement provides evidence of its commercial direction and customer activity; the financing amount is not a measurement of installation reliability or customer payback.
Separate the equipment decision from the service agreement. Request an acceptance test covering the required part family, cycle time, quality checks, and fault recovery, then establish who maintains the gripper and updates the application after a product change. A modular arm is valuable only if modifying the installation is affordable in practice. Compare the full recurring service cost with the engineering and maintenance work your own staff would otherwise perform.
5. Flexiv
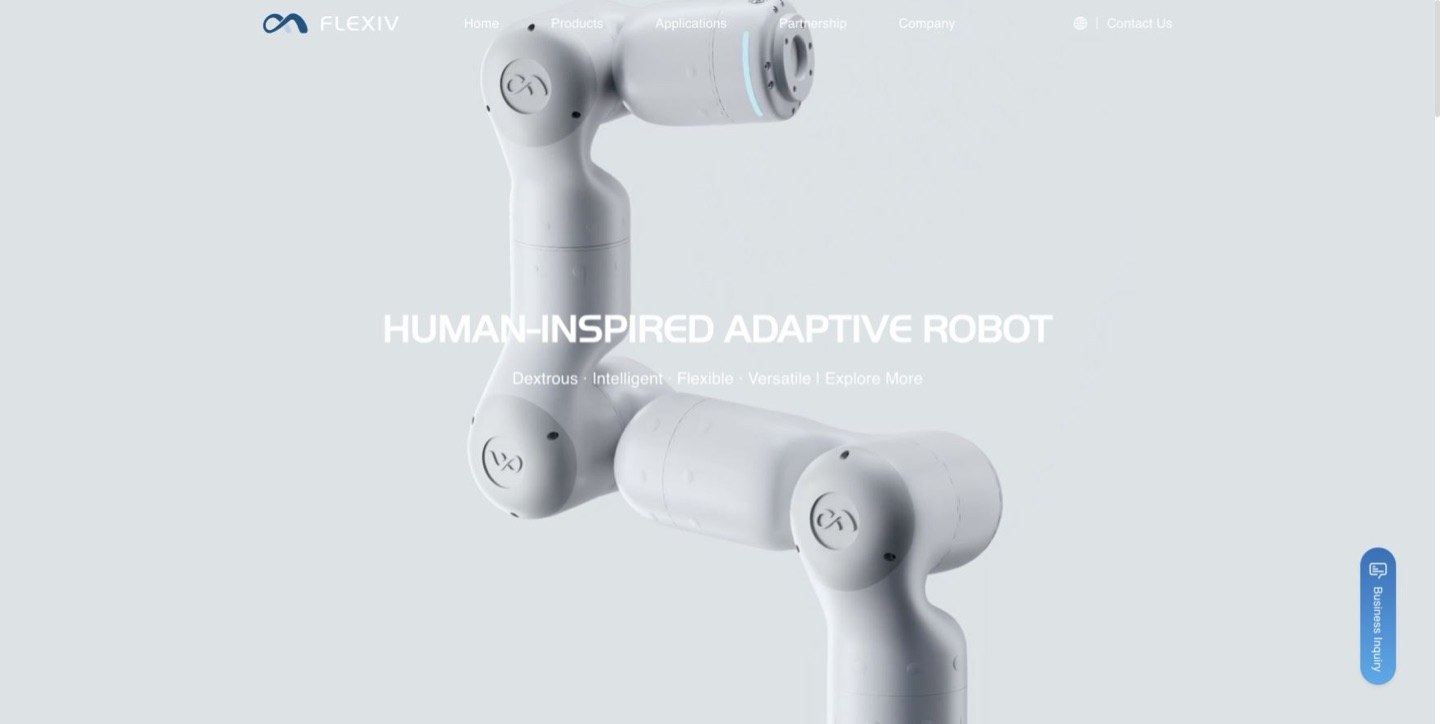
Application examples
Force-controlled adaptive arms address contact-intensive work, including connector insertion and battery-pack assembly. Its applications illustrate an alternative to position-only automation; published examples are vendor-reported.
Flexiv is particularly relevant to contact-rich assembly: tasks in which seeing the target is insufficient and the robot must also manage the forces involved in touching or inserting a part. Its automotive application examples include connector insertion and battery-related assembly. These are vendor-reported examples of an approach, not a common benchmark proving performance across every connector, tolerance, or production line.
An evaluation should use the buyer’s real parts across the allowed tolerance range. Record successful insertions, damaged components, retries, and how the robot detects a jam. Excessive force can turn a seemingly fast cycle into expensive scrap; overly conservative settings can reduce throughput. The practical advantage to investigate is whether force control handles variation that would otherwise require tighter fixtures or frequent manual correction, while still meeting the plant’s quality criteria.
Warehouse logistics: move and fulfill
Purpose: unload trailers, sort packages, move totes, and coordinate storage. Adaptation: package mix, conveyors, warehouse software, traffic, and exception handling. Measure accepted cases per hour, assistance time, and cost per case.
6. Dexterity
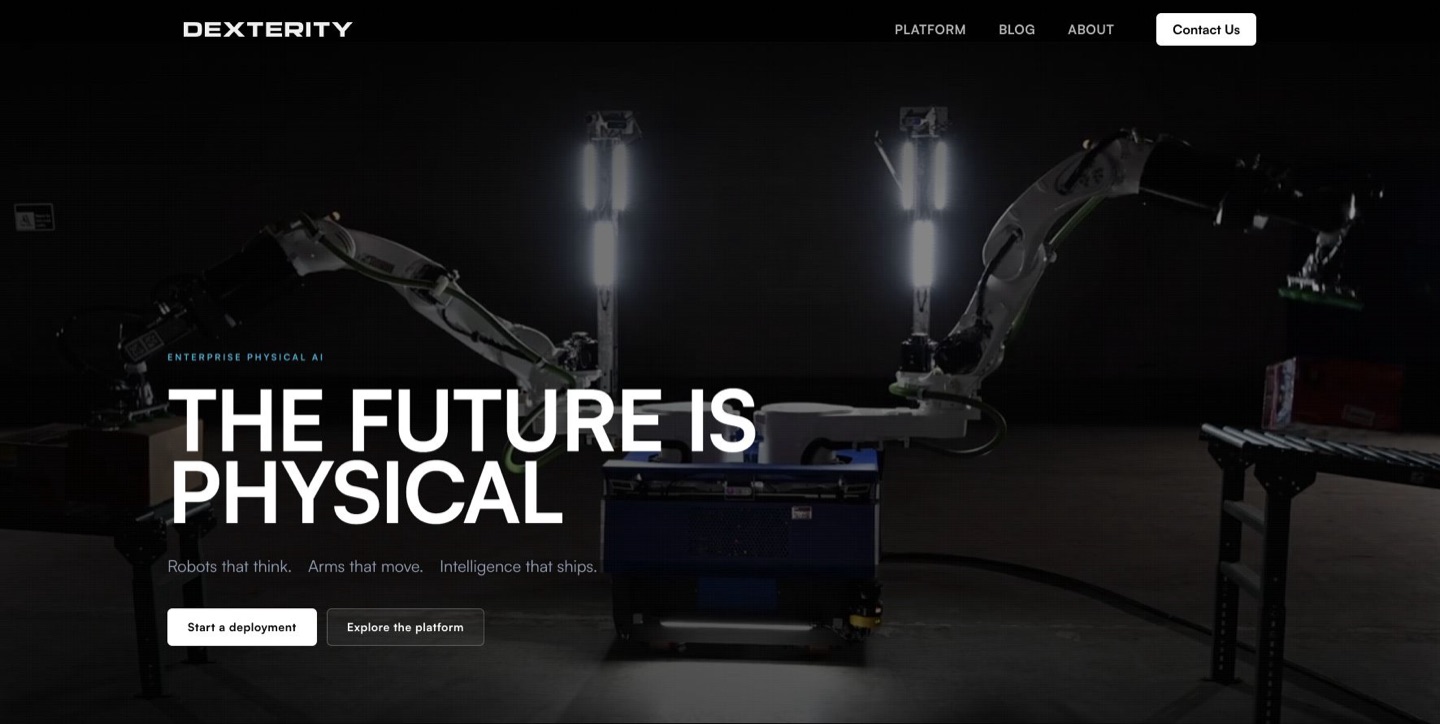
Production reported
AI-guided robots load, unload, and handle changing parcels. Named logistics customers and reported production use make it worth tracking; compare accepted throughput across your actual package mix.
Dexterity targets the variability of parcel handling: the robot has to perceive an item, choose a grip, and place it within a larger material-flow system. Its platform evidence is relevant to a logistics operator because it discusses production use, rather than only isolated laboratory picks. However, a successful deployment with one package mix does not establish the same capacity for soft bags, damaged cartons, or unfamiliar dimensions at another site.
Build a trial from the actual inbound mix and retain difficult packages in the denominator. Measure accepted cases per hour after rejected items, recovery, and downstream waiting. Also specify where exceptions go and who clears them. A system that moves parcels quickly but repeatedly stops the conveyor can shift labor elsewhere instead of removing the bottleneck. Integration with surrounding equipment is therefore part of the evaluation, not a later purchasing detail.
7. Ambi Robotics
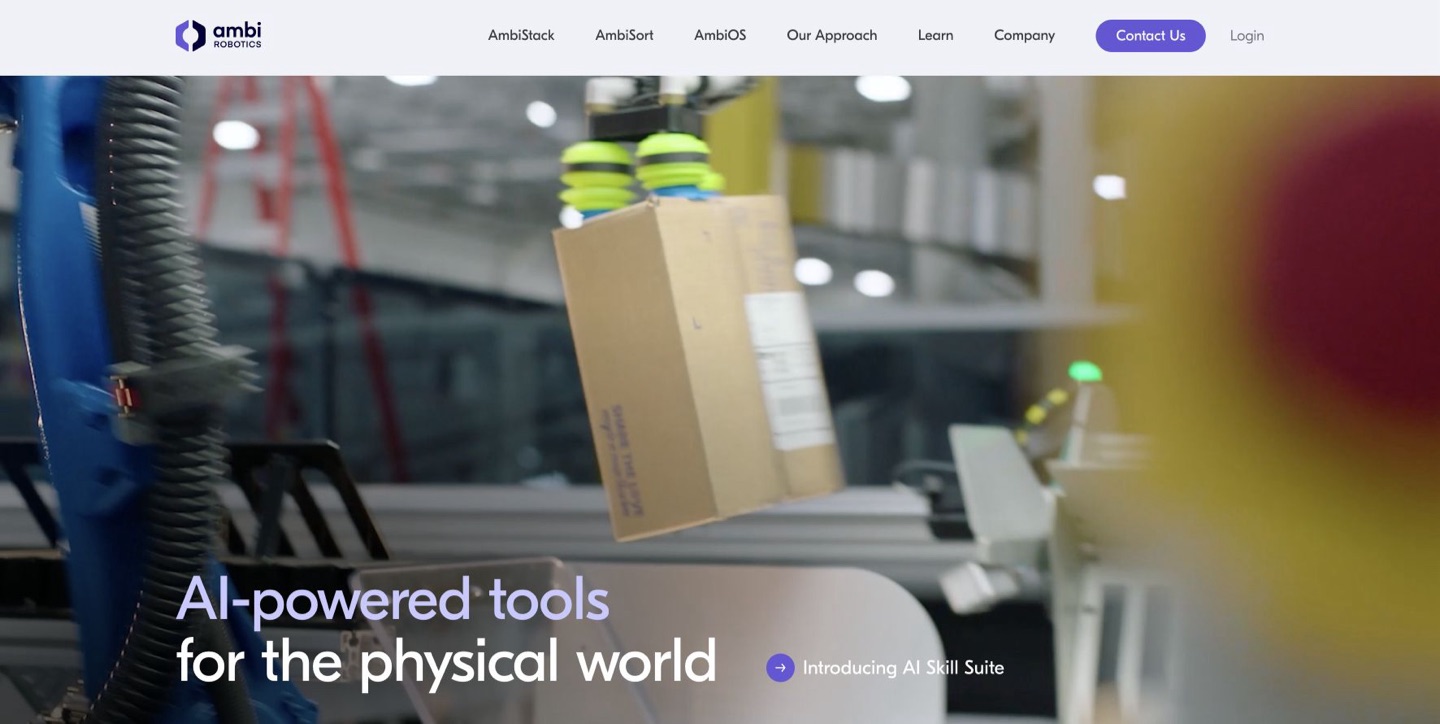
Commercial integration
Learned perception and manipulation power parcel sorting and stacking. Its June 2026 integration with Pickle connects unloading to pallet building; customer identity and operating economics were not disclosed.
Ambi Robotics focuses on the sorting and stacking work that follows parcel arrival. Its June 2026 integration with Pickle Robot connects unloading to pallet building, illustrating how separate robotic systems can cover consecutive tasks. The announcement is useful evidence of system integration; it does not publish enough customer economics to establish a universal savings figure or the throughput of every combined installation.
Test the connection between the two stages, including conveyor accumulation, sorting destinations, pallet changes, and recovery when either robot stops. Faster unloading has little value if the stacking stage cannot absorb the flow. Buyers should ask for sustained output of complete, acceptable pallets under their own carton mix, alongside assistance time and damaged cases. This makes it possible to compare an integrated line with smaller automation steps at the actual bottleneck.
8. Pickle Robot
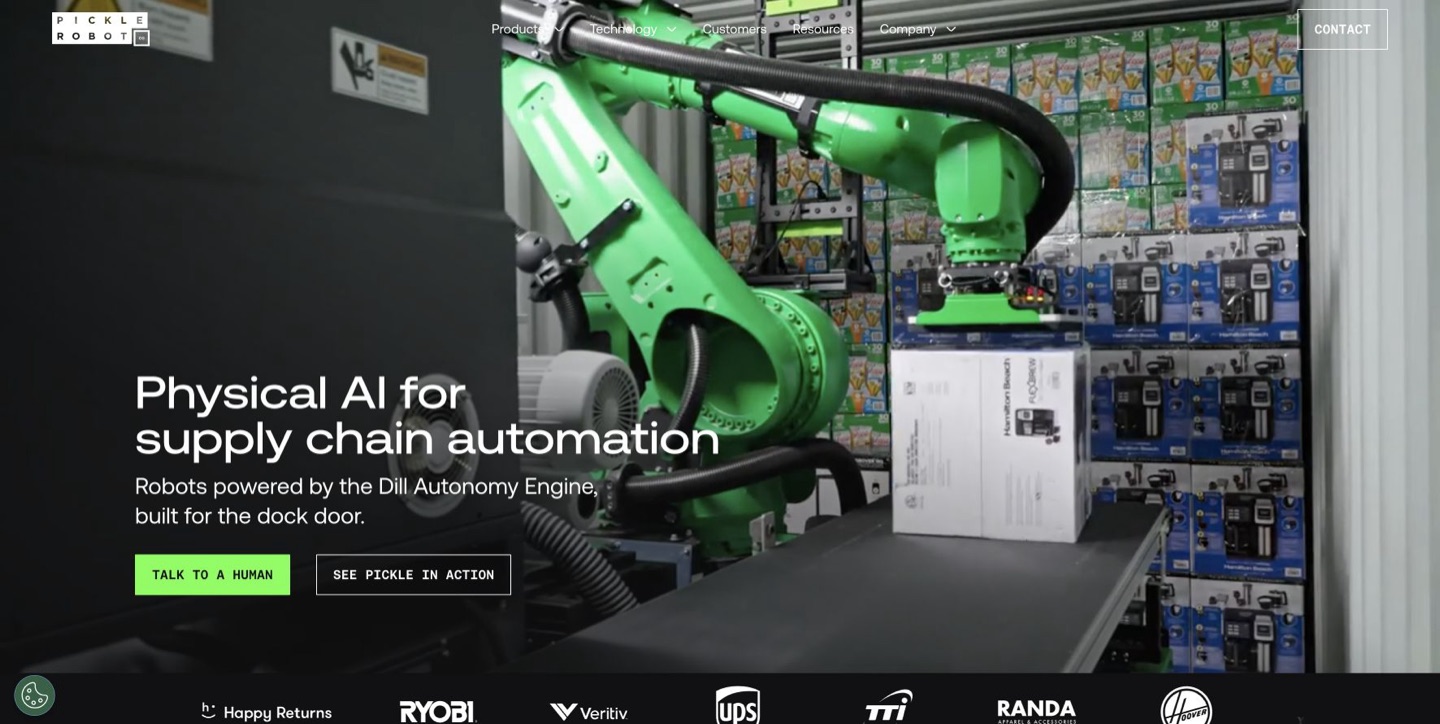
Named customer use
Robots unload loose cases from trailers and containers. UPS is a named user; package variation, human exception handling, and downstream capacity still determine each installation’s useful throughput.
Pickle Robot addresses a specific, labor-intensive boundary: moving loose cases out of trailers or containers into warehouse handling equipment. That narrower task makes the commercial question easier to define than “automate the warehouse.” Its customer page describes operating installations and separately identifies units on order. Orders and planned expansion should remain separate from robots already doing work.
Evaluate complete trailers, including irregular stacks, difficult surfaces, and the last cases that are harder to reach. The relevant metric is the time until the trailer is ready to release, with all manual exceptions included. Check dock compatibility, conveyor placement, operator access, and how damaged or unsupported packages are handled. A high picking rate during an easy portion of the load can otherwise conceal a slow end-to-end unloading process.
9. Mytra
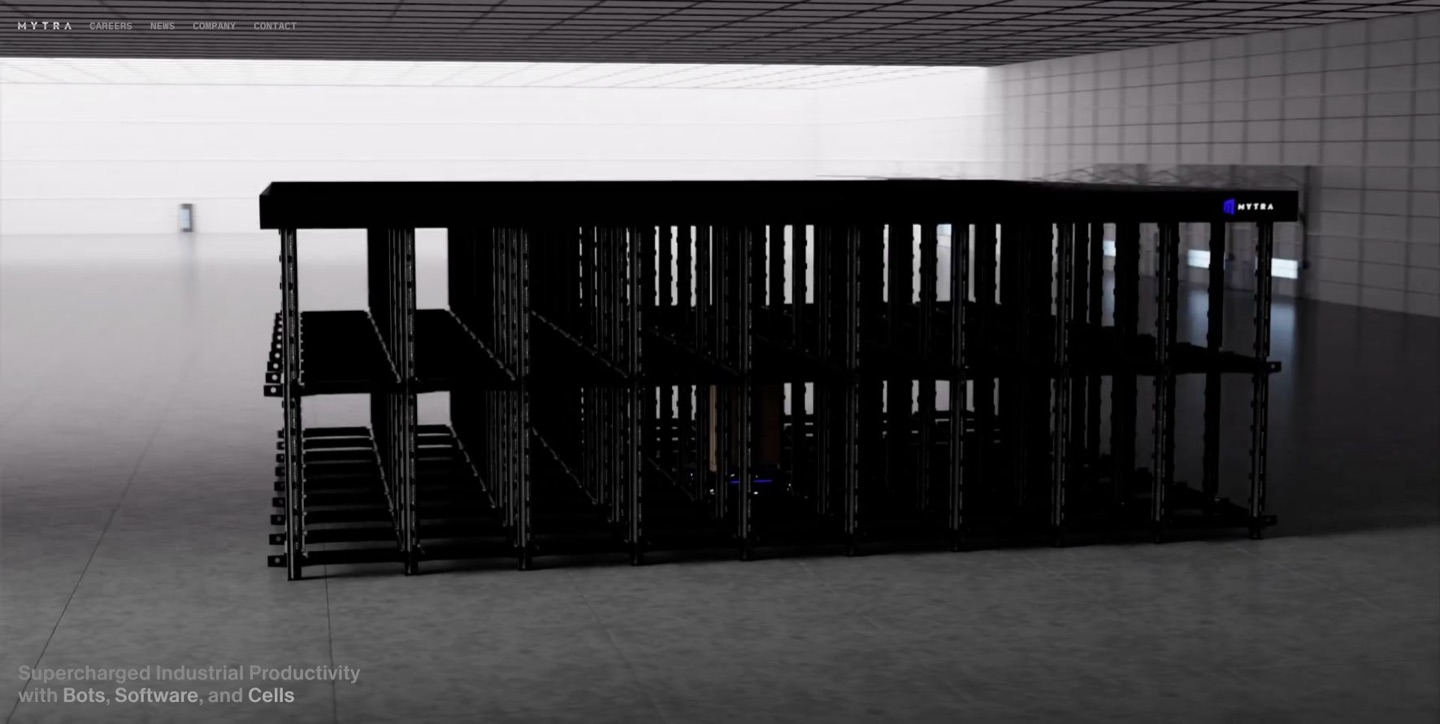
Early production
Mobile bots, modular storage cells, and adaptive routing move materials through engineered storage. Reported pilot and production sites support the approach; contracted expansion should remain separate from live capacity.
Mytra changes the storage-and-movement system itself, rather than adding a single arm to an existing station. Its January 2026 announcement distinguishes two shipped pilots, a new production site, and a much larger signed deployment. That distinction is central to reading the evidence: contracted scale indicates demand, while live installations provide the basis for examining operating performance.
For a warehouse owner, the decision combines storage density, retrieval speed, and the disruption of installing new infrastructure. Test the order mix at peak demand, not just how much material fits in the structure. Ask what happens when a robot or storage location becomes unavailable, and how staff recover inventory. Evaluate phased installation, warehouse-software integration, and service access alongside labor savings; a denser system must still deliver the right stock when it is needed.
10. Agility Robotics
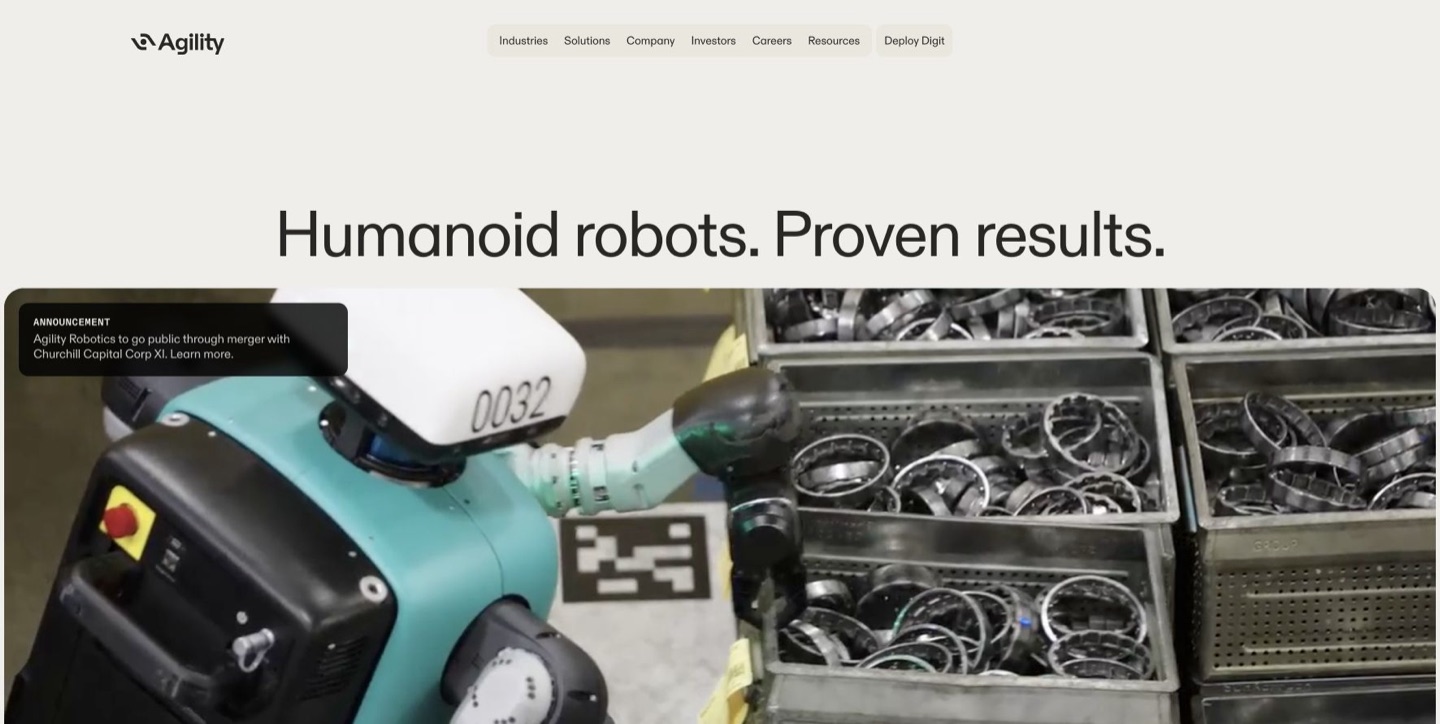
Commercial workflow
Digit transfers totes between mobile robots and conveyors. Agility reports over 100,000 totes moved at GXO, providing a commercial reference for a bounded humanoid workflow.
Digit’s GXO example is a concrete humanoid workflow: transferring totes between mobile robots and a conveyor. Agility’s reported milestone of more than 100,000 tote moves demonstrates repeated activity in that application. It is a cumulative count, so it should not be read as an hourly rate, an unattended-operation percentage, or a financial return without the corresponding operating hours and support requirements.
This is most relevant where equipment built for people leaves a handling gap between two already automated stages. A pilot should measure how frequently Digit waits for arriving totes, needs assistance, or interrupts downstream flow. Compare those results with a fixed transfer station and any layout changes it would require. The value of the humanoid form depends on avoiding enough redesign or handling enough variation to justify its added complexity.
Agility’s June 2026 proposed public-listing transaction remained pending in the official materials reviewed.
Agriculture: grow, weed, and harvest
Purpose: reduce repetitive field work and apply treatment precisely. Adaptation: crop type, terrain, weather, season length, and farm equipment. Measure hectares or accepted harvest per hour, crop damage, and whole-season costs.
11. Carbon Robotics
Commercial equipment
Machine vision identifies weeds for laser removal. LaserWeeder G2 offers a concrete crop-management business case; compare weed control, crop compatibility, field speed, and seasonal utilization on the target farm.
Carbon Robotics combines plant recognition with laser treatment, making the distinction between crop and weed part of the physical action. LaserWeeder G2 is commercial equipment, but the relevant fit still depends on the crop, planting pattern, and field conditions. The linked product page is a manufacturer’s description; its performance claims should be checked against the grower’s own seasonal weed-control requirements.
Evaluate treated acreage and surviving weeds together. A fast pass is not useful if another treatment is needed, and avoiding crop damage matters as much as removing weeds. Include tractor requirements, transport between fields, maintenance, and the number of workable days in the season when estimating utilization. Compare whole-season cost per acre with the current combination of cultivation, hand labor, and other treatments rather than assuming every avoided manual task becomes an equal cash saving.
12. Burro
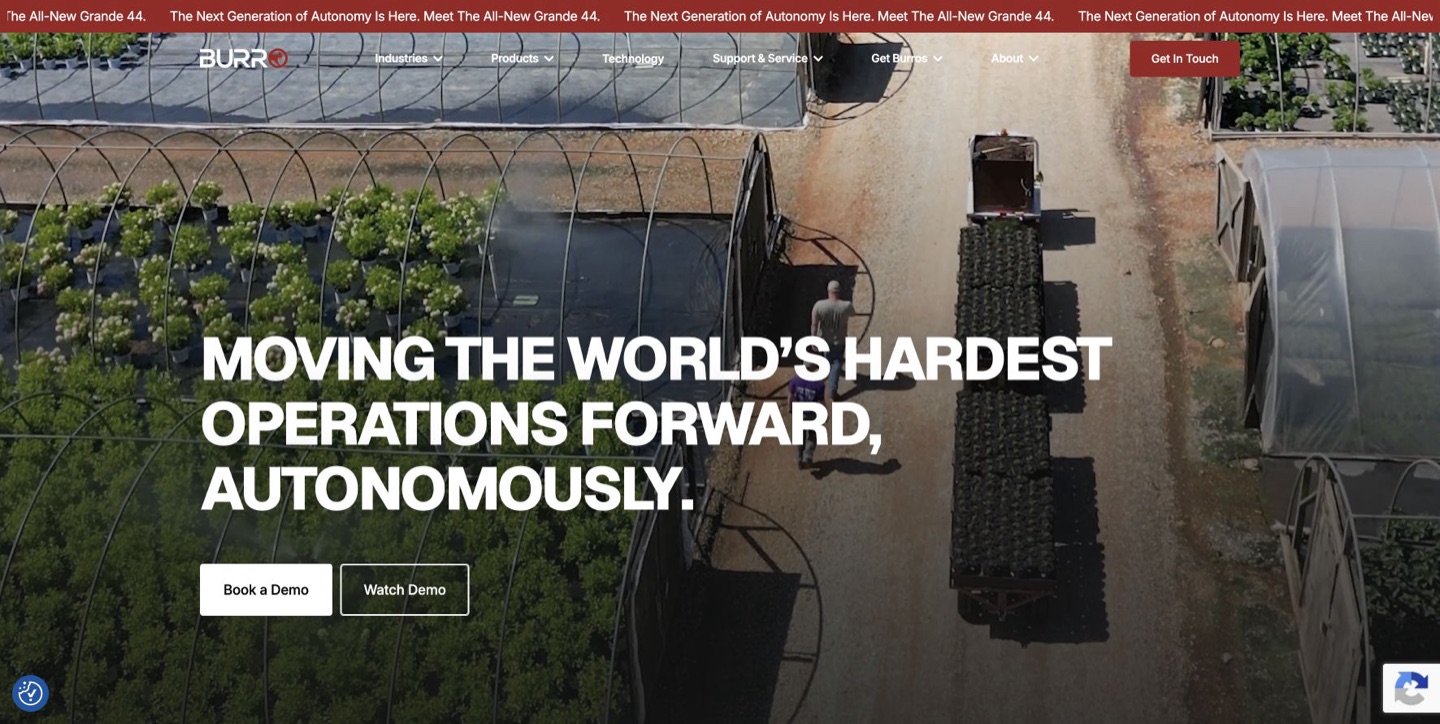
Deployed fleet
Autonomous carriers move crops and tow loads across farms and nurseries. Its established fleet provides operating evidence; the newer Grande 44’s announced delivery schedule should not be treated as completed rollout.
Burro tackles carrying and towing around farms and nurseries, where workers can spend substantial time moving harvested produce or materials instead of tending crops. The important business distinction is between evidence from its established fleet and the delivery plans for the newer Grande 44 platform. A product announcement describes intended capacity and availability; it does not confirm that all announced units are operating at customer sites.
A useful trial follows workers through a complete workday: loaded trips, empty returns, waiting, charging, and route interruptions. Measure additional productive crop work and total trips completed, with supervision included. Check turning space, gradients, wet surfaces, and how the robot and people share narrow routes. This approach shows whether autonomous transport removes a real bottleneck or merely changes who waits for the next load.
13. Aigen
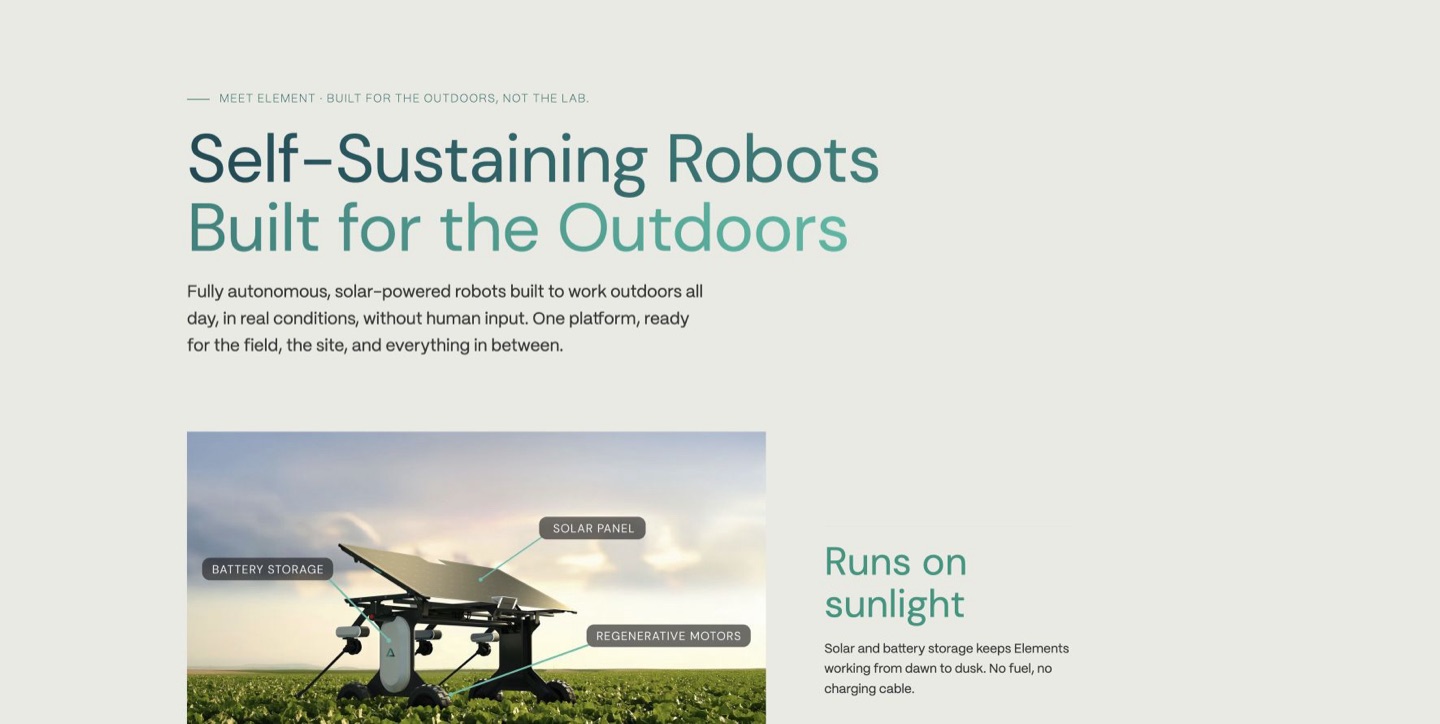
Named farm evaluation
Solar-powered Element robots identify and mechanically remove weeds. Bowles Farming’s cotton-field evaluation provides a named reference; wider availability and performance need confirmation for each crop and field.
Aigen’s Element combines solar power, visual identification, and mechanical weed removal. The Bowles Farming cotton-field account gives the reader a named setting in which to understand the approach. It remains evidence of an early evaluation; it does not establish equal effectiveness across other crops, soil types, or weed pressures, and it should not be presented as broad commercial adoption.
For a grower, examine how the machine fits the crop calendar. Weed control has a useful window, so acreage completed before weeds become harder to remove matters more than hours spent moving. Track crop injury, missed weeds, repeat passes, and interventions after weather changes. Include seasonal energy availability and fleet supervision in the comparison. These measurements test whether a lightweight, distributed approach can cover the required fields at the right time.
14. Agtonomy
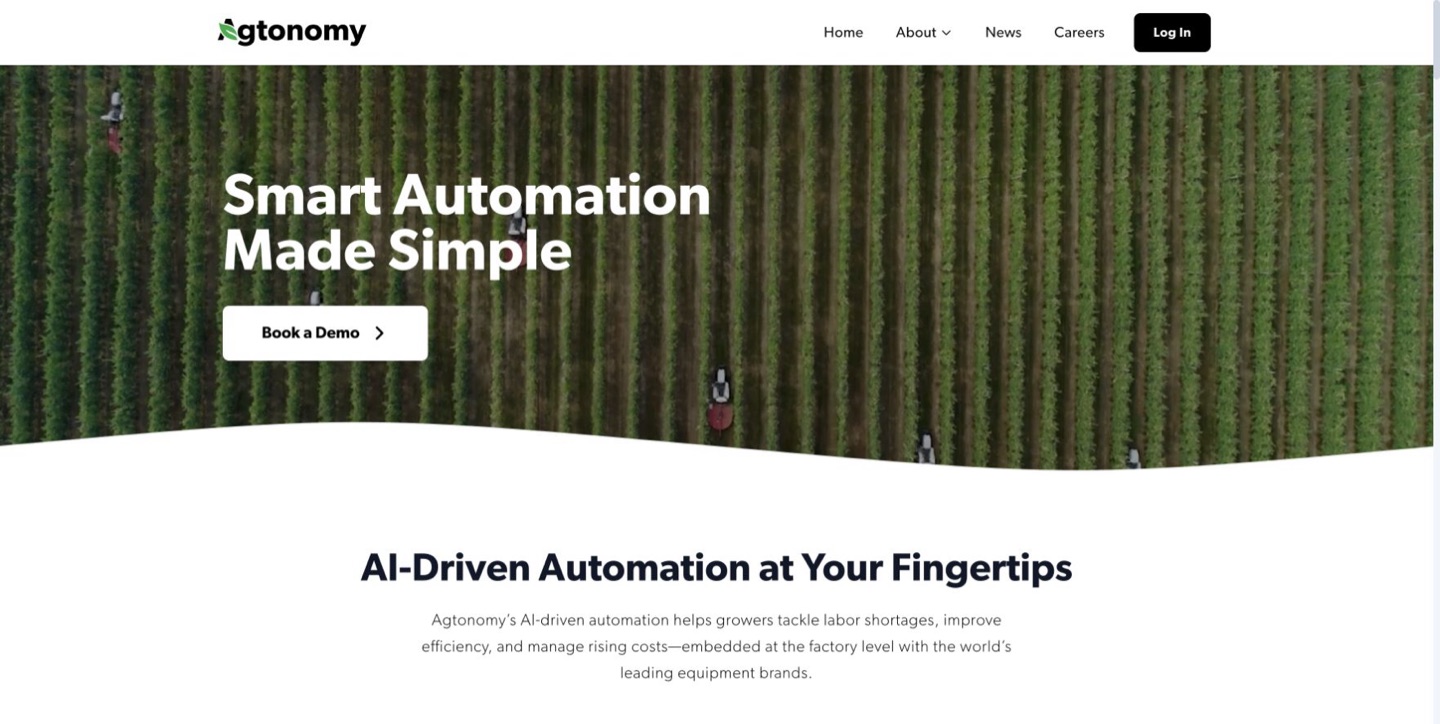
Early commercial use
Adds autonomy to established equipment for mowing, spraying, and hauling. Kubota confirms early commercial deployments, making equipment compatibility, dealer support, and local operating conditions the practical buying questions.
Agtonomy develops autonomy for agricultural equipment and tasks such as mowing, spraying, and hauling. Kubota’s investment announcement describes early commercial deployment, giving the article a named equipment-industry source for its stage. This approach matters to operators who want to automate work around an existing equipment ecosystem, although compatibility must be checked for the specific machine and application.
Start with a repeatable route and a clearly defined implement task. Record the quality of the mowing or spraying result as well as distance traveled autonomously. Field boundaries, people entering the work area, blocked routes, and the procedure for taking control all belong in the acceptance test. Procurement should also establish which organization supports the vehicle, autonomy software, and implement when a problem crosses those boundaries; purchasing a capability does not remove that coordination work.
15. Tevel
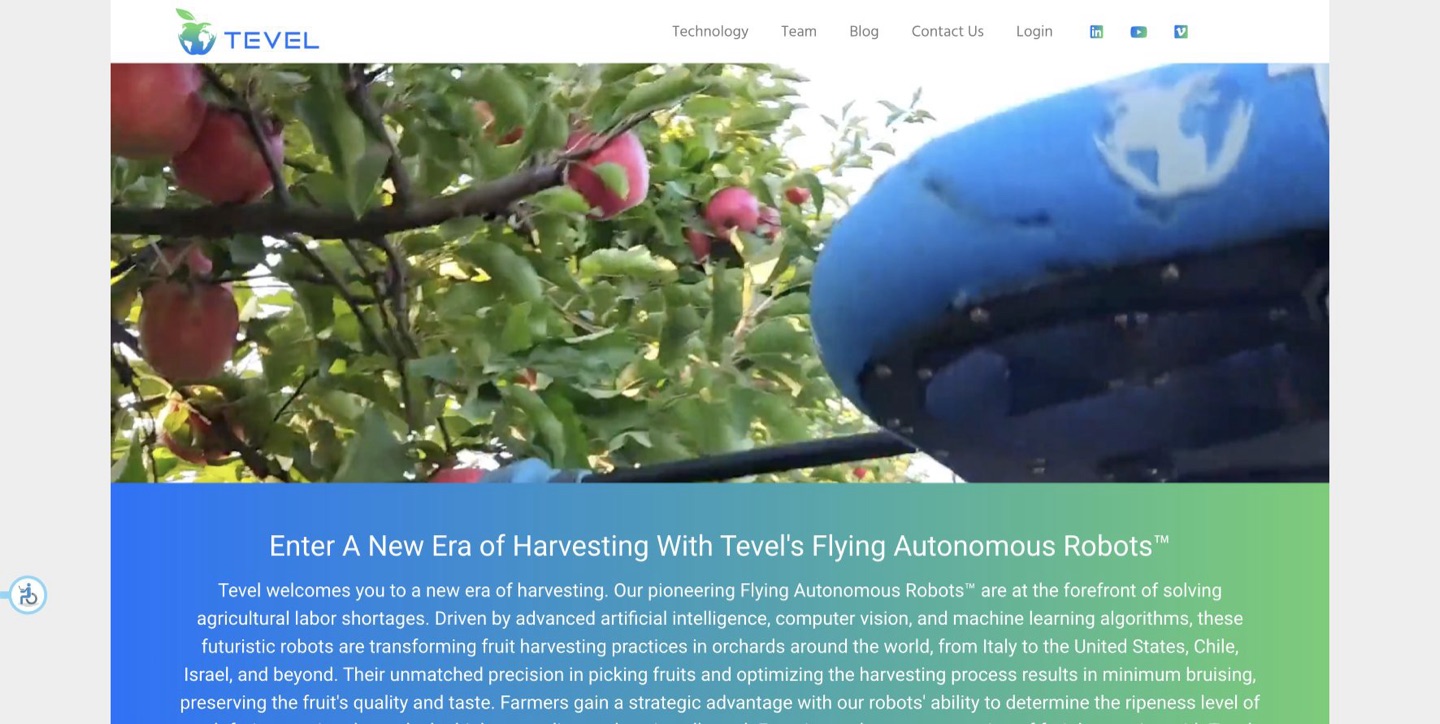
Named orchard partners
Flying fruit-picking robots work with a ground platform and harvest data. Named orchard partnerships provide field evidence; crop suitability, fruit quality, seasonal capacity, and service coverage govern adoption.
Tevel uses flying robots attached to a ground platform to pick fruit, combining access to the tree canopy with perception and harvesting data. Its technology description helps explain the approach, but picking a visible fruit is only part of the commercial task. Orchard structure, fruit variety, ripeness requirements, and handling quality determine how much of the crop can be harvested acceptably.
Test the proportion of marketable fruit collected within the harvest window, including fruit left behind and any follow-up hand picking. Measure bruising and grading outcomes after handling, not only immediately after detachment. Also include platform movement between rows, setup, and service interruptions in the daily rate. The purchasing question is whether the system can deliver enough saleable fruit during a short, variable season to justify its equipment or service cost.
Healthcare: assist procedures and routine collection
Purpose: improve positioning, visualization, and repeatability in defined clinical tasks. Adaptation: intended use, regulatory authorization, staff training, and clinical workflow. Supervised automation and surgeon-controlled assistance are distinct operating models.
16. Mendaera
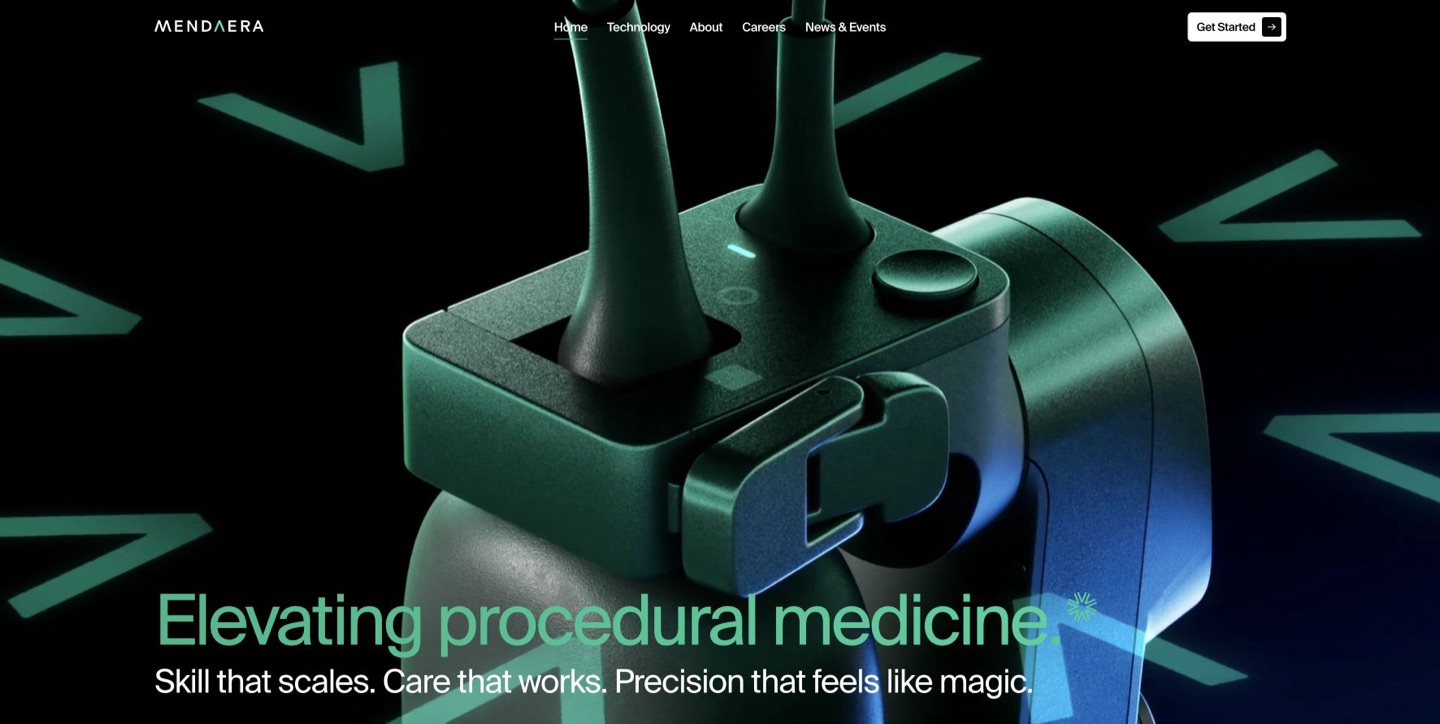
FDA-cleared / early commercialization
Focalist combines handheld robotics, ultrasound, and guidance software for needle placement. The clinician controls insertion; its appeal is assistance within existing procedures, rather than autonomous treatment.
Focalist assists the translation from an ultrasound image to a needle trajectory while the clinician advances the needle. Mendaera’s study announcement reports technical success in 60 of 61 procedures performed by 11 physicians across several specialties. This is a small feasibility study described by the manufacturer, not evidence that the device improves every clinical outcome or replaces procedural expertise.
For a hospital evaluation, distinguish successful access from patient outcomes, procedure time, and the training required for routine use. The study’s population and procedures should match the intended application, and the current cleared indication should govern use. Operationally, ultrasound availability, sterile preparation, setup, and escalation when guidance is unsuitable all affect the workflow. These are reasons to evaluate the system with the clinical team rather than infer staffing savings from the technical-success percentage.
17. Moon Surgical
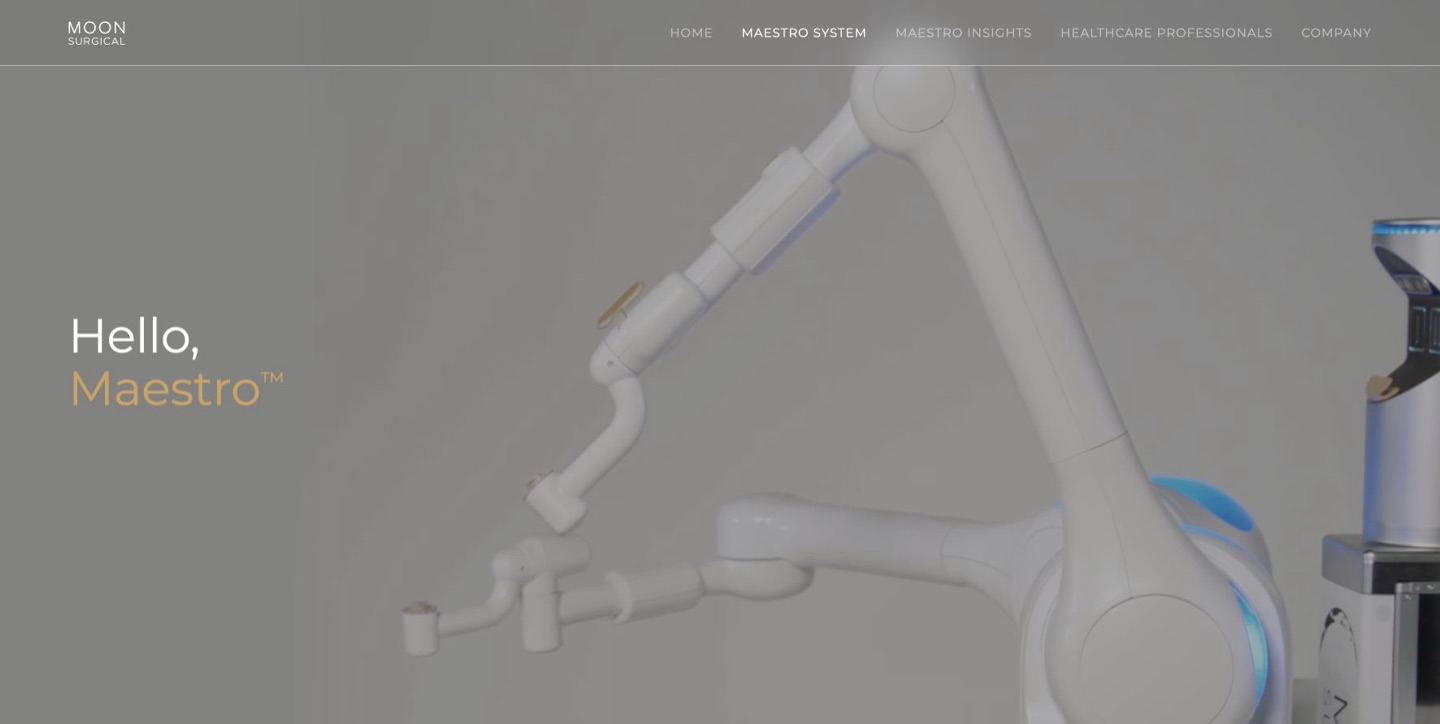
US / EU offering
Maestro supports laparoscopic instruments while ScoPilot adds AI-assisted camera control. The platform is offered in the US and EU; surgeons remain responsible for the procedure.
Maestro supports laparoscopic instruments, while ScoPilot adds AI-assisted camera control within that surgeon-led workflow. The linked FDA-clearance announcement concerns a specific capability on a specific platform. It should not be generalized to autonomous surgery or to authorization for every proposed feature and jurisdiction. The surgeon remains responsible for the procedure and the decisions made during it.
The practical evaluation concerns the operating-room team: how the equipment is positioned, how camera control changes, and how staff regain or change control when needed. Include setup and turnover time as well as intraoperative use. Compare the assistance provided with the current instrument-support workflow, using the procedures covered by the applicable authorization. A useful purchasing case needs evidence of workflow benefit at that hospital; technical novelty alone does not establish shorter procedures or better patient outcomes.
18. Noah Medical
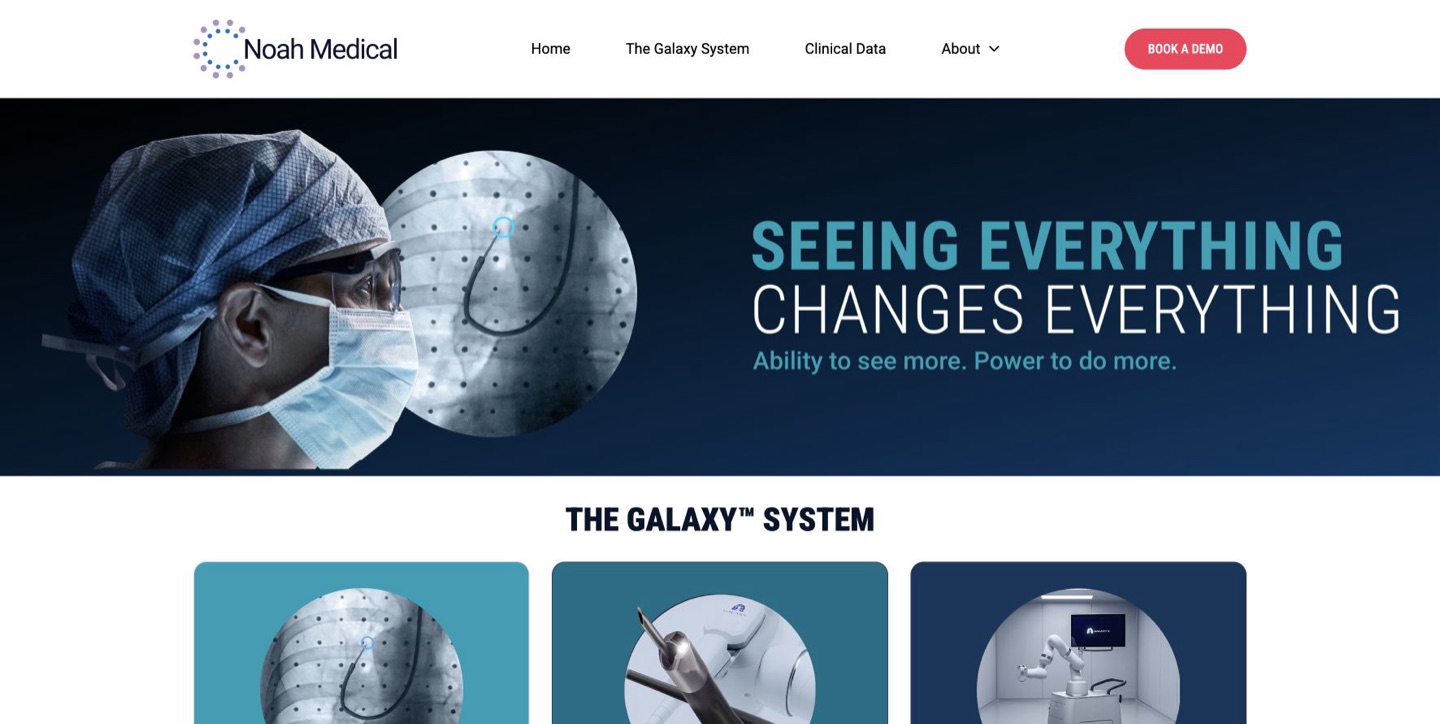
Physician-operated system
Galaxy combines robotic bronchoscopy with imaging and tool localization to help physicians biopsy lung lesions. It illustrates image-guided clinical robotics, not autonomous diagnosis; evaluate device-specific evidence and requirements.
Also review the FDA’s April 2025 quality-system and reporting warning. No linked closeout was found in this review. FDA letter.
Galaxy combines physician-operated robotic bronchoscopy with imaging and tool localization for lung biopsy. The role of the technology is to support navigation and tissue sampling; it should not be described as independently diagnosing cancer. The linked product materials explain the system’s intended workflow, while the FDA warning-letter link above provides a separate regulatory record that buyers should review on its own terms.
Clinical evaluation should separate reaching a target, obtaining an adequate sample, and establishing a diagnosis. Those outcomes depend on more than navigation alone. A hospital also needs to assess imaging access, staff training, procedural setup, consumables, and what happens when the planned target cannot be sampled. The cited warning letter does not itself establish that clearance was revoked or that every issue has been resolved; obtain current regulatory and manufacturer documentation for a procurement decision.
19. Vitestro
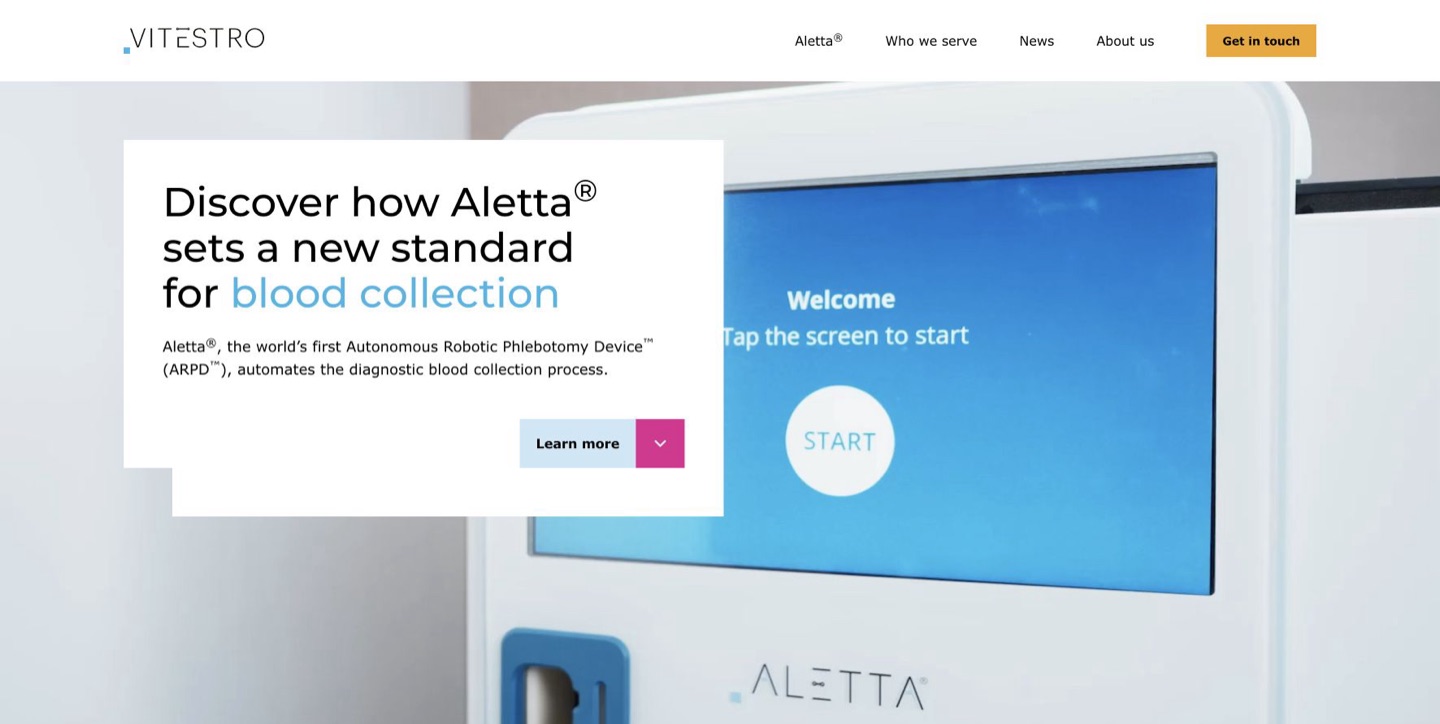
FDA De Novo: Aug 2026
Aletta automates diagnostic blood collection using imaging, AI, and robotics. FDA De Novo authorization arrived in August 2026 for adult outpatient use under trained supervision; European deployment precedes its planned US commercial launch.
The FDA’s August 19, 2026 authorization covers Aletta for adults in outpatient settings under a supervisor trained in phlebotomy. The device identifies a suitable vein and performs the collection sequence; the supervisor initiates sessions, checks tube collection, and remains available. The authorization therefore concerns supervised automation within a defined setting, not an unstaffed blood-draw service for all patients.
The operational question is whether a clinic can integrate patient preparation, cleaning, tube handling, and exceptions into a reliable flow. Measure completed collections per staffed hour and the patients who need another approach, not just successful draws after the device proceeds. Regulatory authorization and a completed US commercial rollout are separate milestones. Buyers should confirm local availability, training, service arrangements, and current labeling before using this example in a capacity plan.
20. ForSight Robotics
Clinical development
JASPER targets surgeon-controlled cataract surgery. ForSight reported 26 patients in its early clinical experience; the platform remains in development and is not FDA-cleared or commercially available in the US.
JASPER applies surgeon-controlled robotic assistance to cataract surgery. ForSight’s reported early 26-patient experience is a clinical-development milestone, not evidence of routine commercial availability or a large comparative outcomes trial. The company’s materials state that the system is not FDA-cleared or commercially available in the United States. That boundary is essential when comparing it with the cleared systems in neighboring sections.
For a healthcare strategy team, the immediate use of this example is to understand a developing approach and the evidence still needed. Relevant questions include comparative outcomes, surgeon training, procedure duration, recovery from interruptions, and compatibility with the clinical workflow. A development-stage platform should not be entered into a near-term purchasing or staffing plan as if delivery, authorization, and operating economics were already established. Follow published clinical evidence and jurisdiction-specific authorization as separate milestones.
Inspection: observe assets and find problems
Purpose: collect repeatable site data and direct human attention to anomalies. Adaptation: terrain, sensors, connectivity, maintenance systems, and operating permissions. Measure coverage, actionable findings, false alarms, and staff time per round.
21. Gecko Robotics
Named industrial agreement
Inspection robots collect asset-condition data for Cantilever analysis. The NAES agreement provides a named commercial reference; the AI value is especially visible in turning measurements into maintenance decisions.
Gecko pairs robotic inspection with asset-condition data and its Cantilever software. The NAES agreement is relevant because it connects inspection technology to a named industrial operator and a maintenance context. The announced deal value represents the agreement’s scope; it is not a count of completed inspections, recognized revenue, or verified savings at every participating facility.
The business case begins after data capture: did the inspection reveal a condition that changed a maintenance decision? Evaluate coverage, repeatability, access requirements, and how engineers connect findings to a work order. Compare the entire outage or inspection workflow with the existing approach, including preparation and follow-up. More measurements are useful only if they improve decisions about repair, replacement, or continued operation, so buyers should request examples that link a detected condition to an actual action.
22. ANYbotics
Named operating case
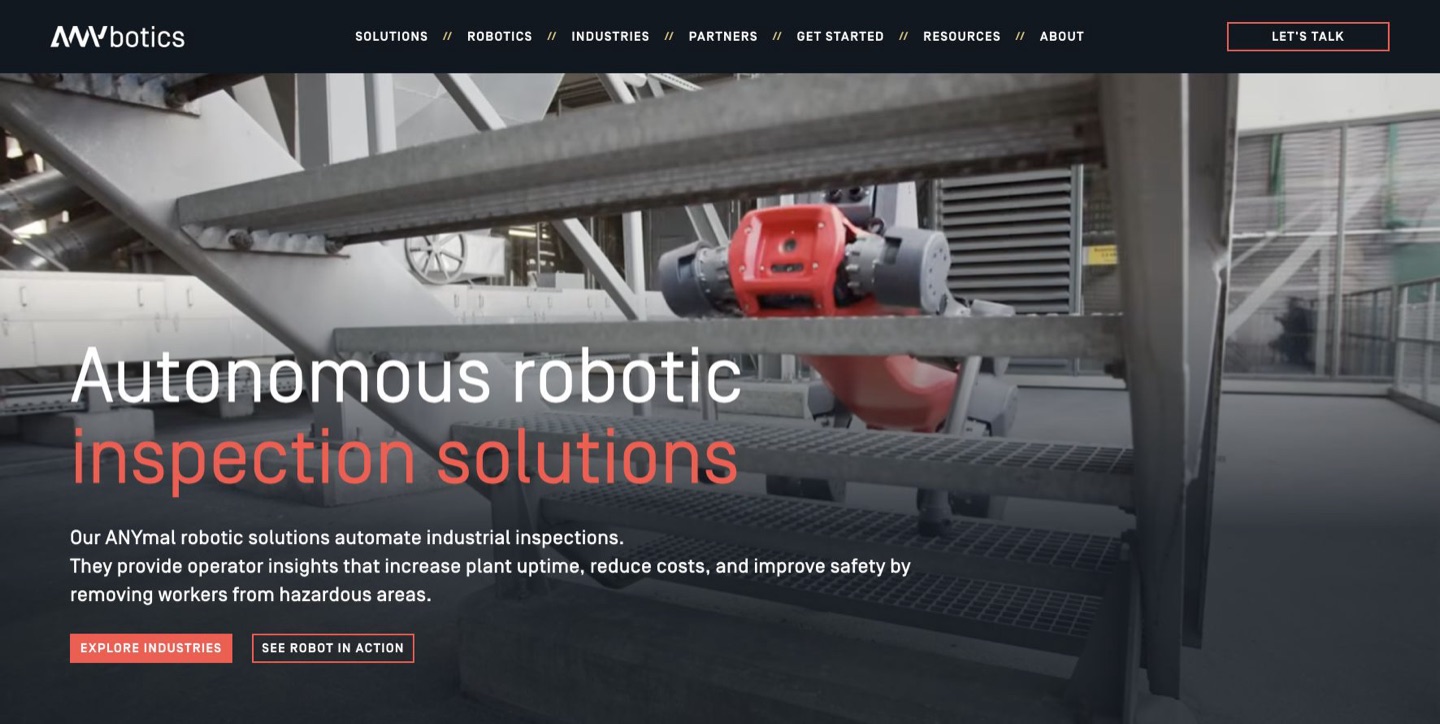
ANYmal performs recurring inspection rounds using visual, thermal, acoustic, and gas measurements. Vigier Ciment provides a named operating case; verify the robot variant, site conditions, and required certification.
ANYmal performs repeatable inspection rounds using sensors suited to the application. The Vigier Ciment operating case is useful because it describes use at a named industrial site over time, where access routes and inspection points matter as much as locomotion. It should not be treated as evidence that every ANYmal variant carries the same sensors or is certified for every hazardous environment.
Start with the actual inspection route: stairs, doors, surfaces, charging location, and the instruments or assets to be observed. Compare missed readings, false alarms, and human follow-up with the current rounds. A robot that reliably reaches the point but cannot obtain a readable measurement has not completed the task. Confirm the required sensor package and site certification, then test whether the resulting data reaches the maintenance team in a form it can act on.
23. Percepto
Utility deployment
Autonomous drones and AIM software help energy operators detect equipment anomalies across dispersed sites. Utility deployment provides a reference; flight permissions and site conditions define the usable operating scope.
Percepto’s drones and AIM software address inspection across dispersed energy assets. The value proposition combines repeatable image collection with identifying changes that deserve attention. Its utility deployment materials provide evidence of that workflow, but the operation of a drone at one approved location does not establish permission to use the same flight pattern at another site or across a wider fleet.
Evaluate coverage under the site’s actual weather, communications, and operating restrictions. Track the time from image capture to a verified issue and a maintenance response, including false alarms. Ask which flights still require human involvement and what happens when weather or connectivity prevents collection. Compare that complete service level with manual inspection. Plans to expand a drone fleet should remain distinct from current coverage and measured availability at the facilities being considered.
24. Ascento
Supported service / trials
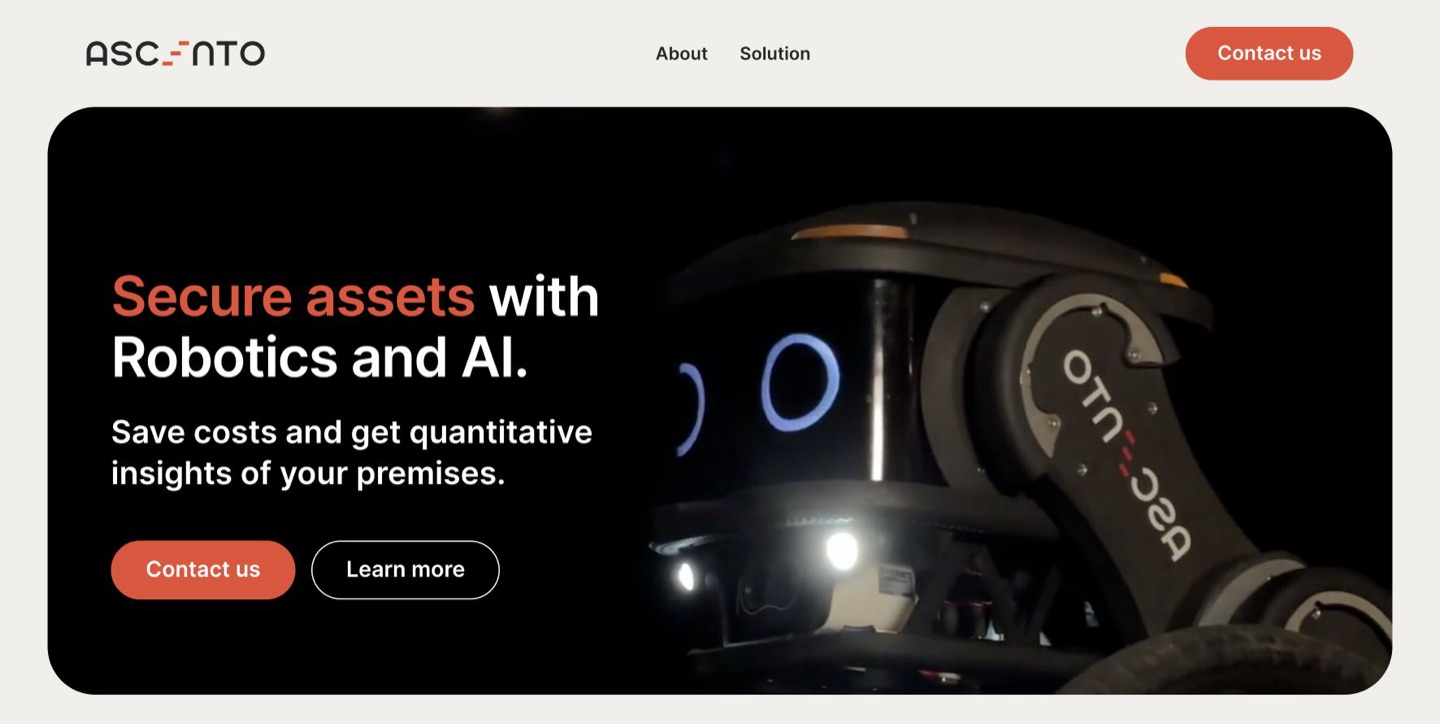
Wheeled robots monitor outdoor sites, doors, and thermal anomalies through a supported service. Securitas testing provides a named reference; its role is observation and reporting, with human response.
Ascento illustrates robotic patrol as part of a staffed security service. The Securitas trial provides a named setting for examining outdoor observation and monitoring, while the robot’s role remains detection and reporting within a wider response process. A patrol robot should not be evaluated as though noticing an open door or an anomaly automatically resolves the incident.
For a site trial, define the observations that matter, the routes and times to cover, and the person responsible for responding. Measure missed events, false alarms, and time to a useful response alongside patrol completion. Check weather, thresholds, ramps, charging, and areas the robot cannot access. This makes the service comparison concrete: how much reliable coverage is added, and how much operator attention is required to turn the robot’s observations into effective security work?
25. FieldAI
Construction deployments
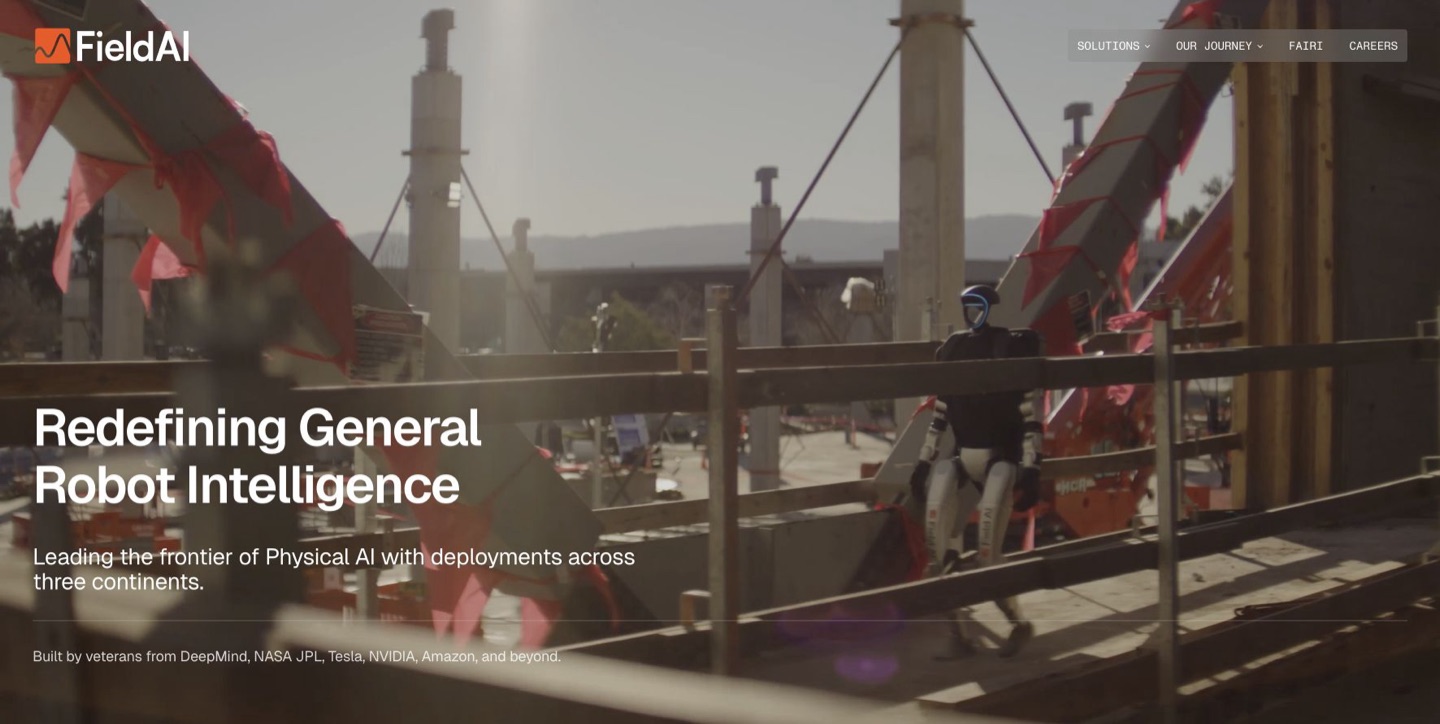
Autonomy software enables different robot bodies to navigate changing sites and collect data. Big-D describes construction deployments; wider ambitions for material handling should be distinguished from those reported tasks.
FieldAI develops autonomy across robot platforms, with Big-D Construction providing a named deployment setting. Construction is a useful test of adaptation because routes and obstacles change as work progresses. The linked account concerns that operating direction; future ambitions such as broader material handling should not be counted as functions already delivered at every site.
A construction buyer should specify the current job—such as collecting site data—and judge it independently of the platform’s longer-term roadmap. Test changing access routes, temporary obstacles, loss of connectivity, and how staff retrieve or stop the robot. Then examine whether the collected information enters an existing inspection or project-management process. The practical benefit depends on reducing the cost of a useful site task, rather than simply demonstrating that the same autonomy software can run on different robot bodies.
Three business trends that matter
Reusable models can lower the starting cost of development. NVIDIA’s GR00T workflow and Google’s Gemini Robotics 2 illustrate progress in adapting perception and control. Both still require customer-specific evaluation; access to a model is not a finished installation. NVIDIA’s development guide , Google’s July 2026 announcement .
Integration and service can be valuable businesses. GXO’s multi-year agreement with Agility illustrates robotics-as-a-service: equipment, coordination, and continuing support around a defined task. The agreement does not disclose price or payback. GXO announcement .
Operating evidence matters more than launches. Amazon’s Blue Jay page was updated in February 2026 to say the system was no longer used in operations. The reason was not established there. For any supplier, track repeat deployments, renewal, assistance requirements, and cost per accepted task. Amazon’s updated announcement .
A quick ROI check before buying
The following example is entirely hypothetical, in US dollars. Assume $180,000 for equipment, integration, and initial training; 4,000 baseline labor hours annually at $35 per hour; and $42,000 in annual software, maintenance, energy, and human assistance.
Productive coverage is the share of baseline work completed to the required quality after downtime and unsupported cases.
| Calculation | 80% coverage | 50% coverage |
|---|---|---|
| Gross annual capacity value | $112,000 | $70,000 |
| Less annual operating cost | $42,000 | $42,000 |
| Annual net benefit | $70,000 | $28,000 |
| Simple payback | 2.6 years | 6.4 years |
Net benefit = baseline hours × coverage × hourly value − operating cost. Payback = installation cost ÷ positive annual net benefit. Under these assumptions, a three-year payback needs about 73% productive coverage.
Released capacity becomes cash savings only when it avoids a real expense. The example holds operating cost constant and excludes financing, tax, depreciation, and residual value; actual assistance costs may rise when performance deteriorates.
Before scaling, record accepted output, human assistance, rework, recovery time, and total cost across representative shifts. Compare conventional automation and process improvements with the proposed AI system. A valuable pilot resolves a purchasing decision.
Research and source notes
Official company websites, customer reports, industry statistics, and analyst publications support the claims. Company results remain attributed, forecasts are estimates, and startup status can change after the cutoff.
The charts are drawn from explicit data and an editorial taxonomy. Website screenshots document the reviewed pages; they are not original product photography or endorsements.
For teams coordinating suppliers across languages, VoicePing’s AI meeting notes and transcription tools can support project documentation. The robotics examples here are third-party products.